Showing posts with label Luna-Resource. Show all posts

Thursday, December 11, 2014

ESA to explore lunar probe partnership with Russia

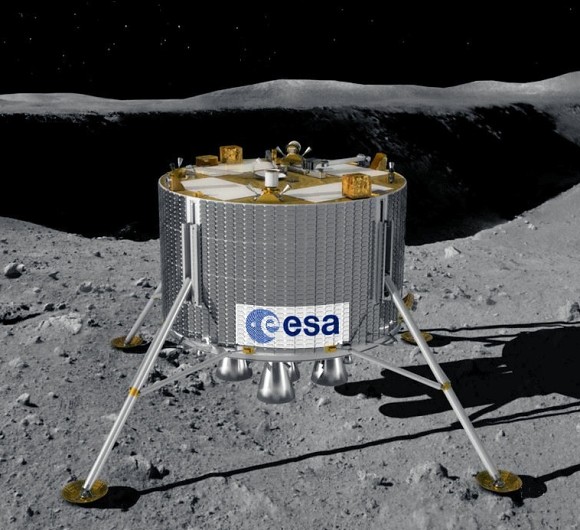
Ten years after planning got underway to place an ESA lander on the rim of Shackleton crater, the design of the MoonNEXT probe was improved by development of the ESA's ATV resupply ship. Still the program was scrapped. But, even as tensions continue between European Union  partners and Russia, ESA's managers have agreed to investigate joining forces with Roscosmos in Russia's lunar program, forestalled by loss of partnership with India, the problem-plagued Fregat vehicle and tight budgets [ESA/Astrium].
Elizabeth Gibney
NATURE

Science ministers in Europe have resurrected plans to explore the Moon’s surface — and the only strategy currently on the table is to join two uncrewed Russian missions. The developments, which follow the shelving of a proposed European Space Agency (ESA) Moon lander two years ago, come amid growing political tensions between Russia and Western nations.

On 2 December, at a meeting in Luxembourg to determine ESA’s policy, the space agency got the go-ahead and funding to investigate “participation in robotic missions for the exploration of the Moon”. Science ministers from the ESA member states did not approve collaboration with Russia specifically, but at the meeting, ESA scientists presented a proposal to join Russia on its missions to put a lander and a rover on the Moon’s south pole.

Money for lunar exploration will come from a pot of €800 million (US$980 million) contributed by ESA’s member states and dedicated to international space exploration; the pot will primarily pay for activities on the International Space Station and the development of a propulsion module for NASA’s Orion spacecraft, which is eventually designed to carry astronauts to deep space, and was tested on 5 December in an uncrewed space flight.

"There be dragons here," no longer applies to the Moon's nearly always, or permanently, shadowed areas at polar latitudes. The Vision for Space Exploration, before it also was scrapped, developed inertia for a brief second golden age of lunar exploration, and it prioritized scientific goals there.

Above, the state of our knowledge about the Moon's south pole in 1994 is compared with where this knowledge base stands today, illustrating one vast improvement in our understanding of the Moon gained at low cost and with great efficiency
 
[NASA/GSFC/JPL/DOD/USGS/Caltech/Arizona State University].
In the 45 years since astronauts first walked on the Moon, no European country or space agency has launched a mission to the Moon’s surface. And no lander or astronaut has been to the lunar south pole, a region thought to contain ice and thus deemed a probable spot for any future permanent lunar base. A 12-kilometre-deep crater there might provide access to material from the Moon’s interior, also making it attractive for scientific study, says Ian Crawford, a lunar scientist at Birkbeck, University of London. The ancient material could reveal details of the collision between a Mars-sized planet and early Earth that is thought to have produced the Moon. “The idea that we've ‘been there and done that’ did last for a long time, but that’s gone away now,” says Crawford. “The Moon still has a lot to tell us.”

Read the full article at NATURE, HERE.

Tuesday, December 17, 2013

Rogozin renews call for Russian lunar exploration, base

Luna-Grunt - Rover Configuration
Russia's space program suffered a huge set back to a renewed lunar exploration effort with the loss of the Phobos-Grunt sample return mission in 2011. A joint mission with India designed to ferry the ISRO Chandrayaan-2 lunar rover to the Moon's surface was cancelled and the Grunt standard prototype lander was returned to the drawing board. Above, a 2010 notional view of a Grunt descent stage delivering rover to the Moon [Anatoly Zak/RussianSpaceWeb].
MOSCOW, December 17 (RIA Novosti) – Russia should consider farsighted space projects such as building a manned outpost on the moon, a senior Russian defense official said Tuesday.

“We must formulate practical plans from conceptual projects and fantasies,” said Deputy Prime Minister Dmitry Rogozin, who oversees the defense and space industry.

Rogozin suggested the Russian space agency Roscosmos and the recently launched Future Research Fund (FPI) should work in tandem on developing such projects.

The FPI – patterned on the United States’ Defense Advanced Research Projects Agency – began distributing grants in April to fund farsighted defense projects. The fund will disburse $70 million this year.

“Many organizations are unfortunately stuck in their busy routines and they have no time to stop and think about new projects,” said Rogozin, who made a similar appeal in September last year for a Russian lunar base to reinvigorate the country’s space aspirations.

On Saturday the 140-kilogram Chinese lunar rover Jade Rabbit made the first soft landing of any probe on the moon in nearly four decades. China is the third nation to achieve a soft lunar landing after the US and the Soviet Union.

Related Posts:
A Russian Moon? Dwayne Day, The Space Review (January 28, 2013)
ESA lunar lander axed (November 21, 2012)
Rogozin presses lunar base, Chandrayaan-2 delayed (September 12, 2012)
Soyuz replacement delayed until 2018 - Popovkin (July 19, 2012)
Craters near Lunokhod-1 officially named (July 3, 2012)
Is there money on the Moon?  Joshua E. Keating Foreign Policy (June 21, 2012)
Russian outlines spaceflight plans to 2030 Marcia S. Smith SpacePolicyOnline (April 29, 2012)
Russian Academy plans Lunokhod-3 and 4 (April 9, 2012)
Popovkin: 'To the Moon in Seven Years?' (February 8, 2012)
"Boy, that sure looks like Luna 9!" (December 3, 2011)

Thursday, September 13, 2012

Rogozin presses Russian lunar base, Chandrayaan-2 delayed by Proton and Phobos-Grunt investigations

As Russia’s Deputy Prime Minister Dmitry Rogozin continues to deployment of a manned base lunar base 'by 2020,' ISRO declines comment on Chandrayaan-2 delay 'until 2016' India's follow-up to its successful first lunar orbiter, together with a small remotely operated rover landed on the Moon by a Russian spacecraft had previously been delayed to 2013 and 2013 [ISRO/IKI].
According to Russian and Indian sources, Russian Prime Minister Dmitry Rogozin continues to lobby for  a permanent station on the lunar surface "before 2020," calling it an "over-arching task," a "super goal," or очень задача for the Russian state, "stimulating the development of science and industry."

Reports followed an interview recorded on Vesti FM Radio earlier this month.

“Russian cosmonauts learned to work in orbit and gained needed experience there," Rogozin said. "Why shouldn't they try to build a full-scale lunar base to set the groundwork for further leaps in science?”

Indian press reports have covered the interview in context with little more information than previously known about Russia's planned role in Chandrayaan-2. Indian Space Research Organisation (ISRO) chief K. Radhakrishan recently declined comment on reports that the Chandrayaan-2 lunar orbiter, lander and rover mission will now be unavoidably delayed until 2016.

"For Chandrayaan-2, Russia has to provide the lander, and India will build the lunar orbiter and rover," Radhakrishan said. "Russia has said they would come to us with a decision (regarding their grunt-class Luna-Resurs lander) after their reviews.”

Russia is reviewing their inter-planetary missions in light of recent set-backs, particularly following the November failure of Phobos-Grunt  and, more recently, after the failure of Sino-Russian vehicle that was tied to a faulty Proton booster.

The results of at least one such investigation, into the Proton failure, were reported out September 12, according to Anatoly Zak of RussianSpaceWeb.com.

Chandrayaan-2 had already been delayed until 2014, planned for launch on India's troubled Geosynchronous Satellite Launch Vehicle (GSLV).  Radhakrishnan confirmed ISRO will prepare the booster, the lunar orbiter and rover, but he declined comment on a report from Russia that India’s second lunar mission must be delayed until at least 2016.

Lev Zelyony, head of the Russian Space Research Institute (IKI), said in February the Luna-Resurs lander might not be ready before 2016.

“There were plans to launch the Luna-Glob and Luna-Resurs missions in 2015,” Zelyony told RIA Novosti in February. “But dates may have to be moved, because the NPO Lavochkin-design for the ill-fated Phobos-Grunt vehicle are integral also to Russia's planned unmanned lunar projects and "clearly need to be reviewed.”

Sunday, April 29, 2012

Russia outlines spaceflight plans to 2030

Marcia S. Smith
SpacePolicyOnline

Russia's space agency, Roscosmos, has posted its long term plans for human and robotic spaceflight on its website.  The plan outlines Russia's space goals through 2030.

The document is in Russian, but Anatoly Zak of Russianspaceweb.com provides a summary of its key points in English along with his analysis of their feasibility.

Read the article, HERE.

Monday, April 9, 2012

Russian Academy plans Lunokhod-3 and 4

Schematic representation of the Luna-LD-Rover concept, as presented to the Lunar Exploration Analysis Group (LEAG) annual meeting in 2010. The overall robust rover and experiments, designed for long-duration exploration through several lunar days and nights, builds on the successful Lunokhod scenarios [Institute for Space Research - Moscow].
The Russian Academy of Sciences has prepared early plans for two Lunokhod-class unmanned lunar rovers, "Lunokhod 3 and Lunokhod-4," to “work the Moon” between 2020 and 2023, this according to a document obtained by the news agency RIA Novosti. A stationary “landing station” is pegged for 2024 “as the first steps to form the future manned lunar base” sometime later.

As the heart of the Soviet Union, Russia was the first and only nation to deploy unmanned rovers on the Moon, Lunokhod-1 in 1970 and Lunokhod-2 in 1973.

Russia completed the last soft landing and sample-return mission on the Moon, Luna 24, in 1976.

The Luna-Glob polar lander, together with its Russian orbiter, originally planned for 2012, and the Luna Resurs polar lander, with India's Chandrayaan-2 orbiter and mini-rover were planned for 2013. Set backs caused by systemic problems, highly manifested in the Phobos-Grunt failure, have resulted in a national reexamination of Russia's unmanned and manned space exploration plans, beyond participation in the International Space Station [IKI].
Missions originally developed for 2012 and 2013, Luna-Resurs and Luna-Glob, are apparently to be pushed back to after 2015. Whether India will continue to participate in those early missions is a question still up in the air. In February the India Space Research Organisation (ISRO) postponed indefinitely the Chandrayaan-2 lunar orbiter and rover combination. India’s rover was designed to be ferried to the surface on Luna-Resurs.

“Under the document," obtained by RIA Novosti, core aims of the Russian scientists are to study polar regions of the Moon and gas-dust exosphere,” according to the April 7 news account. An overall goal of the Academy is to collect samples “and find the most comfortable areas for lunar base deployment.

“The lunar rovers and the landing station will form first elements of space infrastructure for a lunar testing area with prospects of deployment of Russia’s lunar base.”

Saturday, December 3, 2011

"Boy, that sure looks like Luna 9!"

Fig. 1  Idealized Google Earth icon of Luna 9, the first soft-landing on the Moon (the first soft-landing anywhere other than Earth), February 3, 1966. The cartoon Russian spacecraft is pinpointed more than 30 kilometers northeast (8.0°N, 296.0°E) of an 'official' landing site (7.08°N, 295.63°E) because investigators say the 'official' coordinates place the lander well beyond the eastern rise, at left on the horizon above. That location doesn't appear to match the landscape seen in the panoramas returned to Earth. The object identified as a likely candidate, at 7.153°N, 295.630°, is less than 2.8 km north of the official coordinates, but at a notably higher elevation on that same rize, perhaps where fewer obstructions are to be found on the local horizon [NASA/USGS/JAXA/Google].
Joel Raupe
Lunar Pioneer

The problems encountered by the Russian Federation after the launch of Fobos-Grunt on November 9, when compared with the apparent ease NASA is experiencing, thus far, in getting Curiosity through the present Martian launch window, might tempt fools to dismiss Russia's interplanetary skill. Russian morale might be threatened but we're reminded yet again that Space is relentlessly intolerant of cutting corners or under-funding. The Great Galactic Ghoul, that cosmic gremlin supposedly spoiling to ruin Mars and Moon missions alike, spends most of its time here on Earth.

Off-planet, when Institutional Memory is applied efficiently, the Russians are a match for anyone.

Friday, December 2 is the 40th Anniversary of the first soft-landing on Mars, and Russia's Mars 3 lander was successful, though the lander operated on the surface only 20 seconds, back in 1971. Saturday, December 3 is the 12th Anniversary of the loss of America's Mars Polar Lander in 1999. Thus, the success of Curiosity is by no means a sure thing. When space exploration begins to look too easy disaster waits patiently at the door.

A planned Russian return to the lunar
surface may ultimately benefit from a post-
Fobos-Grunt shakeout
[RussianSpaceWeb].
The first vehicle soft-landed on the Moon (and the last one landed there, a decade later) were strictly Made in Russia. Embarrassing and often tragic, spectacular failure also often fuels political will, without which governments accomplish nothing.  After a latter-day purge of Russia's unmanned mission contractor NPO Lavochkin, the legacy of Fobos-Grunt may help guarantee eventual success for Luna-Grunt and the other lunar missions Russia has in the works.

If all goes well, beginning next month, the United States will support five spacecraft exploring the Moon simultaneously, the most prominent among them the record-smashing LRO. Following decades of a near total neglect of its hard-won and expensive lunar legacy, America owes a revival of interest in Earth's Moon directly to the loss of Columbia in 2003.

An early priority for LRO was a survey of human artifacts on the Moon. Delivering spectacularly on that assignment were Mark Robinson, principle investigator for the Lunar Reconnaissance Orbiter Camera (LROC), together with his team at Arizona State University. Their most newsworthy success, quite naturally, were many high resolution history-making photographs of the relics and footprints from the Apollo program.

Fig. 2  Planitia Descentus - Latin for Plain of Descent, a human distinction for an otherwise indistinct borderland along the western edge of Oceanus Procellarum, where Luna 9 came to a tilted stop February 3, 1966.  The yellow dot on the rise at center bottom on both maps makes the location of an object that could be Luna 9. These comparative maps of the same 14,300 square kilometer area (centered near 8.48°N, 64.47°W) are (top) LROC WAC DTM  juxtaposed with (bottom) LROC WAC mosaic, each from LROC/ASU QuickMap (250 m/pp resolution). [NASA/GSFC/Arizona State University].
A steady stream of LROC Narrow Angle Camera (NAC) views were released during the LRO Nominal Mission revisiting the remains of a host of U.S. and Soviet spacecraft, both impact craters and the intact sentinel spacecraft themselves following hundreds of lunar days and nights. Each of these Featured Images released by LROC has fired the imagination while calibrating and confirming some very old, often incomplete sets of data.

Finding Lunokhod 1 (38.316°N, 324.996°E), for example, was an overdue accomplishment. It was the first robotic rover on another world, equipped with a laser range reflector that had eluded detection for decades. Its addition to the passive network of reflectors set up by Apollo 11, 14 and 15, together with its French-built twin on Lunokhod 2 allowed the measuring of the Earth-Moon distance to within 3 mm, the missing tolerance needed to test whether a range of physical laws were exclusive to our neighborhood in the universe.

A compendium of LRO's definitive findings, LROC Coordinates of Robotic Spacecraft, put together by Samuel Lawrence at ASU, was released April 5, 2010.

Though the list has not been updated since, it's still spectacular. For the first time, for example, anyone with an Internet connection can see precisely what happened when the third stage of the Saturn V that pushed Apollo 13 around the Moon impacted with the lunar surface. And planetary scientists have a precise date on a fresh impact crater on the Moon, as well; a standard useful for dating optical maturity and space weathering. We no longer have to imagine if the footprints are still there and decades of doubters can precisely see for themselves how the astronaut's surface photography matches the landscapes as seen only 45 (and more recently 25) kilometers away.

Still, the table put together by Lawrence can't yet be comprehensive.

A search for the place where Luna 2 became the first man-made object to impact another world in 1959, for example, is fraught with uncertainty. Those official coordinates are necessarily wide of mark, if only because the precise location of the Moon itself, and its surface, would never again be less well understood than before the Russian measured the time of impact for Luna 2.

A search for Luna 2 using those rounded-off coordinates brings the investigator west of Autolycus, to a 22 square kilometer area where there are at least two, perhaps three, fresh craters with the proper wispy signatures. One of them shows signs of a unique debris field, perhaps dotted with a cluster of the impact-resistant Soviet flag-engraved metal balls reportedly loaded on Luna-2. A surface expedition will be needed, in other words. As amazing as it is, however, even the LROC Narrow Angle Cameras have their limits.

At the very edge of those limits is Luna 9, the 99 kg.lander the Soviets succeeded in soft-landing on the Moon on February 3, 1966. In Multiple NAC footprints covering the target area uploaded to the Planetary Data System, even by April 2010, it was easy to see the LROC team had already earnestly tried to find that historic relic. But Luna 9 wasn't on the list put together by Lawrence.

Fig. 3  A closer look at the Plain of Descent.  The rectangle matches a 2.5 km-wide cross-section of LROC NAC observation M137970706R, the area seen in Figure 6a, below. The small white dot marks a spot less than a kilometer south of the rectangle, the official Luna 9 landing site, and the white dot inside the rectangle marks the location of an "object of interest," something that seems to be a Luna 9, in the two NAC observations detailed below.  The 'mid-morning' view above is a 41-km-wide field of view taken from LROC Wide Angle Camera (WAC) observation M160376850C (604 nm), LRO orbit 8769, May 18, 2011; incidence angle 55.42° with a resolution of 57.55 meters per pixel, from an altitude of 40.49 km [NASA/GSFC/Arizona State University].

As noted expert on lunar artifacts Phil Stooke of the University of Western Ontario put it, finding the very first vehicle soft-landed on the Moon was "problematic," even with the proven sensitivity of the twin LROC Narrow Angle Cameras. 

There is lingering dispute about the true landing site, though the central difficulty in finding Luna 9 is probably the small spacecraft's low profile. Its instrument housing is barely at the half-meter limit to the LROC NAC Nominal Mission resolution. And, because discussing Luna 9 without seeing its mission in the context of the Cold War would be incomplete, a brief comparison with Surveyor, its very real competition, is necessary.

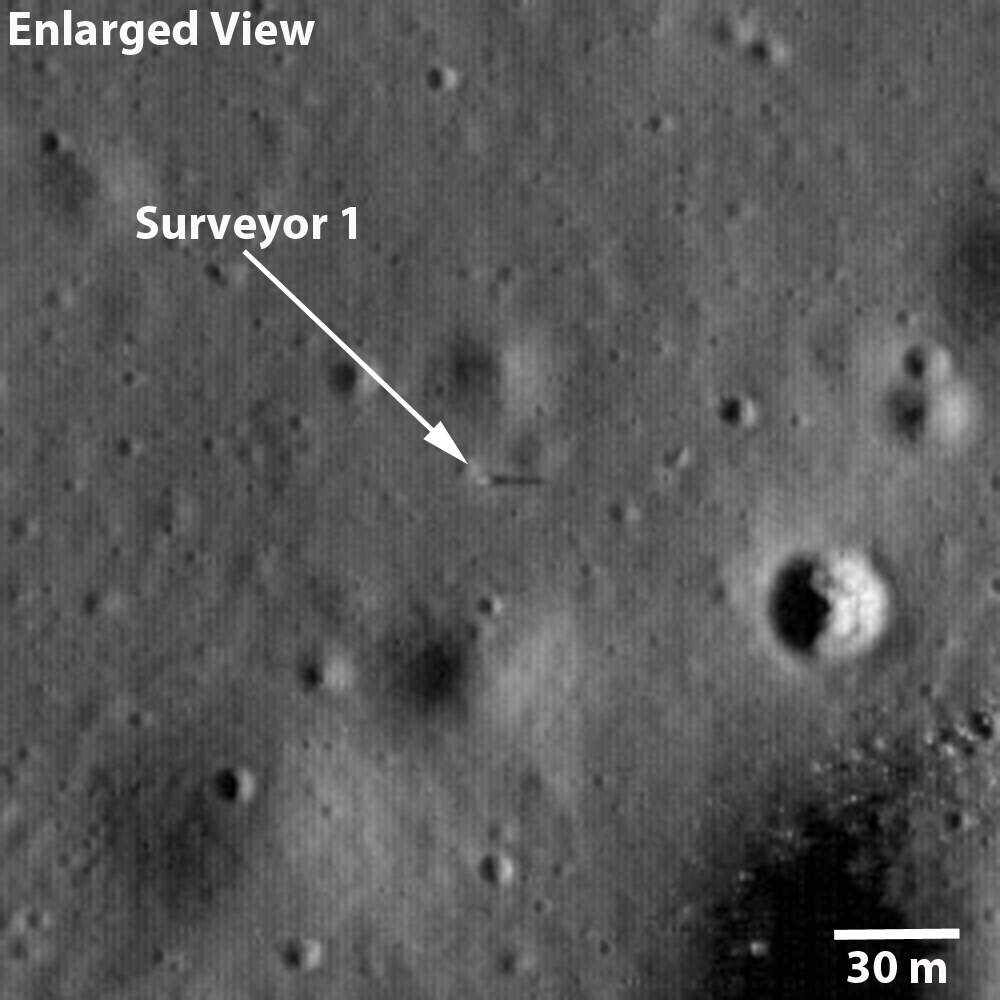
The Russians beat Americans to the Moon in 1966 by only five months. Samuel Lawrence had already written up and released LROC's first views of "Surveyor 1 - America's first soft lunar landing," on September 30, 2009. That observation (M102443995L) swept up the first U.S. lander very early in LRO's Commissioning phase, in orbit 272, when LRO was still flying at twice its Nominal mission altitude, from 102.4 km overhead. That survey of the floor of Flamsteed P was photographed at less than half of the planned LROC NAC resolution; at 1.08 meters per pixel, the Surveyor 1 tripod in profile was barely visible, identifiable mainly in its long shadow at local sunset.The Surveyor design featured a central mast with square solar panels at the top, standing high like a flag. That aided in identifying all five of the successful Surveyor landers, right they sat. 


Unlike its Google Earth icon, seen in Fig. 1, Luna 9 was not standing like an egg, balanced on one hemisphere. After its landing and activation Luna 9 was at tilted, and from slight changes in the background seen in its five photographic panoramas we can tell Luna 9 shifted slightly after deployment.

Fig. 4  Simulated oblique view west by northwest over the area of interest from a point 28 km over the western Oceanus Procellarum. After years of deconstructing the five panoramas captured and returned to Earth by Luna 9, many reliable experts have come to doubt the accuracy of the official landing site (coordinates on the left, at "-1310 m" elevation).  Some believe Luna 9 must have landed somewhere in the plain to the north (on the right, marked "-1640 m").  If the object detailed in Figures 5 and 6 below is Luna 9 then the lander came to rest at a point less than three kilometers and almost due north of the official coordinates ("-1170 m"), and at least 140 meters higher in elevation.  After studying the LROC WAC Digital Terrain Model of the area (Fig. 2) the hills, contiguous with other features surrounding the Plain of Descent, appear to be the highly degraded rim of an ancient, mostly buried crater.  -Image created using ILIADS application, developed by NASA's LMMP project; photography from LROC WAC Global Mosaic with elevations from LOLA altimetry (v.2). [NASA/GSFC/ARC/LMMP/ASU].
The low profile and squat, efficient design of Luna 9 have made it difficult to definitively locate, either somewhere in the expansive plain to the north or near the official position somewhere on a 500 meter high hill, nor on their slopes. All of the area was extensively photographed from LRO, from high altitudes and low, under high Sun and low Sun, with LRO rolled and looking down from directly overhead. If the little vehicle has been captured (which seems certain) what would distinguish its egg shape from thousands of boulders more or less the same size?

It's a safe bet Samuel Lawrence and others on the LROC team encountered this difficulty head-on, with the determination and resourcefulness of a Cold War photo-analyst pouring over U2 photographs of Cuban missile sites. 

In fact, it would be the height of presumption on our part to claim to have done anything more than retraced their steps. It's impossible to believe a candidate object we stumbled on, within their choices of photographic session, hasn't already been considered or scratched off the list. Were it not for something that may turn out to be simply an artifact of digital compression we wouldn't take another look.

Let's just say, "boy, that sure looks like Luna 9!"

What follows are two sets of images, selected from two separate LROC NAC observations, focused on an "object of interest" at sunrise (Figures 5a and 5b), when the Sun was less than 5 degrees over the east horizon, when long shadows allow for depth perception, and then (in Figures 6a - 6d) where, at less than 8° north of the equator, the Sun was high overhead and depth perception gives way to a search for subtle variations in brightness or optical maturity.


Fig. 5a   The full 2.5 kilometer-wide field from LROC NAC M132071202L orbit 4597, June 25, 2010; with resolution greatly reduced from the original 0.48 meter per pixel resolution captured from 40.49 km altitude, incidence angle 85.57°. The yellow rectangle is the area shown at full resolution in Fig. 5b, immediately below. The yellow dot is our "object of interest," so to speak, indicated with an arrow in at full resolution below. The object certainly casts a shadow, as anything with a profile would when caught in naked morning sunshine on the Moon. It is also seemingly brighter than other similarly sized objects in the roughly 238 meter-wide field of view seen below.  [NASA/GSFC/Arizona State University].
Fig. 5b  Full resolution, and very non-definitive rendition of the Object of Interest, again, from LROC NAC M132071202L The object appears to be situated within the west slope of a 10 meter crater, whose interior is very darkened with shadow. Since Luna 9 arrived on the Moon not long after local sunrise, this doesn't help identify the object as Luna 9. The larger, similarly bright object to the southwest is too large to be Luna 9, but its size and location relative to the object of interest makes a case for it being part of the larger lander bus [NASA/GSFC/Arizona State University].
On the 500 meter hills, south of "the plain of descent," under an afternoon Sun:

Fig. 6a  Backing away once again, shifting perspective slightly to the west, with the Sun nearly overhead, this is the field of view within the rectangle back in Fig 3, and slightly west, overlapping the area in Fig. 5a, another 2.5 km-wide area taken this time from LROC NAC M137970706R, orbit 5466, September 1, 2010, from 45.57 km in altitude (incidence angle 29.64°). The area in the white rectangle is the field of view enlarged in Fig. 6b, immediately below [NASA/GSFC/Arizona Sate University].
Fig. 6b  At 40 percent of their original resolution, line 14775 to 15556 by sample 3964 - 4544 from M137970706R. (The dim dark line is an artifact "junction" between line 15000 and 15001). And, like a Russian Doll, the square box above is the roughly 290 meter-wide field of view seen at 100 percent of the original observation's 0.5 meter per pixel resolution seen in Fig. 6c, immediately below [NASA/GSFC/Arizona State University].
Fig. 6c At full resolution, lines 15001 - 15580 by sample 3964 - 4543 from LROC NAC M137970706R. Compare this with Fig. 5b, above and, once again, what is seen under differing lighting conditions on the Moon is clear. When happening upon this candidate object under a high Sun, something catches the eye [NASA/GSFC/Arizona State University].
Fig. 6d  Taking  LROC NAC M137970706R  well beyond its true limit of resolution we stumble upon what might be Luna 9, resting on the west interior slope of a shallow 10 meter crater, perhaps even afterwards sliding slightly between photographic panoramas, February 3, 1966. Under an early afternoon Sun, after being enlarged 400 percent with a super-sampling algorithm, what appear faintly as three of the spacecraft's four instrument-shielding petals (the fourth presumably in its shadow) somehow popped out from the background. No intentional fudging was done to the original brute-force enlargement (See Fig. 7) [NASA/GSFC/Arizona State University].
Fig. 7 A simple enlargement to 400 percent of the half-meter per pixel resolution native to LROC NAC observation M137970706R turned up this object, certainly an oddity if it is not Luna 9. As demonstrated in the hackneyed animated image (Fig. 6d), the object meets the profile, is barely less than 3 kilometers due north of its official landing site, about 140 meters higher in elevation, on a broader slope with presumably less obstructed horizon.

Fig. 8 The view south from Luna 9, February 3, 1966.


Using the popular open-source program Orbital Simulator, "reseferina1" created this interesting simulation of the Luna 9 mission in 1966. Though fun, it too, unfortunately, made the thing look far too easy. The originating YouTube page is HERE.

Friday, September 3, 2010

Chang'e-2 sets stage for future Moon missions


China's second lunar orbiter Chang'e-2 began as back up for Chang'e-1 (2007-2009). Scheduled for a possible October launch, Chang'e-2 should arrive sooner, orbit the Moon closer and gather better data. If all goes well the vehicle should allow rehearsal opportunities for China's first soft landing on the Moon in 2013, and a better camera on Chang'e-2 may gather 1 meter resolution photographs of preferred landing sites.

China's unmanned space program has only one deep space target: the Moon. The United States may be preparing to abandon manned exploration of the lunar surface but the new era of international lunar exploration, a 'second moon race,' continues. India, Russia and China may each have achieved soft landings there before the U.S. deploys the first, if any, of planned nodes for an International Lunar Network (ILN). After Chandrayaan-2 and Chang'e-3, Chang'e-4 may return the first lunar samples to Earth since the Soviet's Luna 24 in 1976.

From Xinhua -- China's second lunar probe, Chang'e-2, will transition much faster than its predecessor, reaching lunar orbit in a shorter period of time, a top Chinese space scientist told Xinhua Friday.

China launched Chang'e-1 from Sichuan October 24, 2007. The first of China's planned unmanned lunar missions ended a 16-month mission March 1, 2009 when it was intentionally de-orbited into Mare Fecunditatis.

"It is estimated Chang'e-2 can reach lunar orbit within five days, compared to 13 days, 14 hours and 19 minutes for Chang'e-1," Ouyang Ziyuan, chief scientist at the China Lunar Exploration Project, told Xinhua.

"China had not been to Moon before Chang'e-1 so we were very prudent and adjusted its transfer orbit in a very slow manner. It traveled 2.06 million kilometers before lunar orbit insertion," Ouyang said. "It's different now. We are more certain about the launch and can send Chang'e-2 directly to the moon, and we have also planned the transfer orbit to reach the Moon within five days."

Plans call for Chang'e 2 to orbit 100 km closer to the moon with a higher resolution camera, he said.

According to China's three-phase lunar exploration 'road map,' the country will first launch the Chang'e-2 and afterward soft-land Chang'e-3 on the moon in 2013 and, in 2017, Chang'e-4 will return a lunar sample to Earth.

Experts have speculated the Chang'e-2 mission will allow China to begin mastering soft-landing techniques for Chang'e-3 and 4, short of terminal descent. Careful lowering of its orbit to rehearse everything short of terminal descent that otherwise might begin after passing perilune could allow low passes over an intended target and an opportunity to take high-resolution photography.


Public mock-up of the China Lunar Exploration Program (CLEP) Chang'e-4, in development for a soft landing on the Moon in 2013. China's methodical dual-track developmental plans, its manned and unmanned (lunar), space programs seem devoted more to engineering design capability over science [Xinhua].

Friday, August 13, 2010

Proposed GLXP rule changes inspire concern

Updated September 15, 2010 1825 UT

Google Lunar X-Prize (GLXP) team SELENOKHOD in Russia demonstrates a test-bed prototype of the lunar rover the group hopes will win a minimum $20 million purse. However, Russian resources now committed to a planned 2013 joint Russian & Indian lunar mission has put a strain on their timetable [Selenokhod].

Peter J. Brown
Asia Times Online

Government space agencies are taking a closer look at the Google Lunar X Prize (GLXP) contest, an international competition to safely land a rover on the moon. Several GLXP teams include space researchers and engineers in Asia on their rosters, and NASA is rolling out a program that might provide US GLXP teams with a $30 million market for their mission data. Other countries may not sit still for long in light of this development.

That is the good news. The not so good news is that as the result of a proposed GLXP rule change, the $20 million GLXP grand prize could be reduced by $5 million if a government-backed lunar mission successfully lands and deploys a rover in advance of any of the 21 GLXP teams accomplishing the same feat. All GLXP teams must be 90% privately funded.

According to the original set of GLXP rules, the grand prize would be awarded to the team that first landed a rover on the Moon and subsequently able to travel at least 500 meters while simultaneously transmitting data and a live TV signal back to Earth. The deadline has been December 31, 2012. If that objective was not achieved, however, a GLXP team could still win a reduced grand prize of $15 million if it fulfilled all requirements by December 2014.

Now, under the proposed so-called GLXP "Master Team Agreement" (MTA), revised rules, including the $5 million cut described above, are taking shape. All remaining prizes, including a $5 million second prize and several bonus prizes, would be unaffected.

Under proposed changes to contest rules, the 2012 deadline is pushed ahead three years to December 31, 2015. However, even that deadline might be extended by the California-based X Prize Foundation (XPF).

Several countries, including the European Space Agency (ESA), are planning to conduct lunar landings over the coming decade. The joint Indian Space Research Organization (ISRO)-Russian Federal Space Agency (Roskosmos) Chandrayaan-2 orbiter and rover / Luna-Resource lunar lander scheduled for 2013, appears first in line.

"Almost every space agency is talking about missions to the lunar surface these days. Putting fixed calendar dates on them is very difficult, though," said William Pomerantz, senior director of space prizes at the XPF.

"We are excited about and are following developments on other fronts, including China's Chang'e 3, Japan's SELENE-2, The Indo-Russian Luna-Resource /Chandrayaan-2, ESA's MoonNEXT, a variety of potential NASA robotic missions and possibly the UK's MoonLite, along with eventual nodes of the proposed International Lunar Network (ILN)."

"At this point, it's difficult to say with certainty which will be which," said Pomerantz

Read the full article, HERE.

Wednesday, August 4, 2010

Luna-Resource & Chandrayaan-2 in 2013

Updated September 15, 2010 1826 UT

Rough notional view of Russia's Luna-Resource lunar lander deploying India's Chandrayaan-2 rover, India's second lunar mission now anticipated in 2013. The Russian lander will carry an IGN-10K neutron generator designed to confirm the presence of water, apparently in vapor form, directly detected by India's Moon Impactor Probe (MIP) near the Moon's south pole in November 2008. [LPRG].

Joel Raupe
Lunar Pioneer

August 3 – The Hindustan Times reports the unmanned Russian lunar lander Luna-Resource, after ferrying and supporting the lunar rover segment of India's Chandrayaan-2 mission, will be an entire stationary mission in its own right, equipped with a neutron generator designed to confirm a presence of water at the Moon’s high latitudes, most likely within the still unsampled 4 billion-year-old South Pole-Aitken (SPA) impact basin.

India’s flag-carrying Moon Impact Probe (MIP), deployed from Chandrayaan-1 in November 2008, appears to have directly detected water in vapor form imoments before its intentional impact near Shackleton crater and the Moon’s south pole.

Chandrayaan-1 was launched by the Indian Space Research Organisation (ISRO) October 22, 2008 and inserted into a polar orbit around the Moon the following November 12.

India's first lunar orbiter completed 3,400 revolutions during 312 days, until all contact was abruptly lost, May 19, 2009. The Moon Impact Probe (MIP) separated from the larger vehicle and soon afterward impacted near Shackleton crater at the Moon's South Pole, not long after Chandrayaan was successfully inserted into lunar orbit.

In 2013, the Indo-Russian Chandrayaan-2 / Luna-Resource (ISRO/Roscosmos) 1,000 kg lunar payload is slated for launch from Sriharikota on the sub-continent’s eastern coast. The six-wheeled ISRO rover, accompanying the Russian lander, is expected to weigh 58 kg.

The Indian rover is designed to operate for a year, traveling 150 kilometers at speeds of 300 meters per (Earth) day, primarily powered by solar energy and juggling the incidence of almost continuous sunlight in and around permanently shadowed regions (PSR's) near the lunar South Pole.

In 2012, the Russian lunar orbiter mission Luna-Glob is being developed to carry four Japan-built impactor-seismographer probes.

The Hindustan Times quotes Yevgeny Bogolyubov, deputy chief designer at All-Russian Scientific Research Institute of Automation (VNIIA), confirming Roscosmos plans "to send to the Moon (Luna Resource) bearing a neutron generator developed by our institute to study the lunar surface.” A similar neutron generator would, he said, eventually be used to study the surface of Mars.

The Press Trust of India reports a "short listing" of instruments to be carried on the Chandrayaan-2 orbiter and rover vehicles launched together with Luna-Resource were to be selected in Bangalore on August 3.

According to ISRO Telemetry Tracking and Command Network (ISTRAC) director S.K. Shivakumar, individual Chandrayaan-2 scientific instruments would weigh between 30 and 35 kg.